Embodied tree of thoughts: Deliberate manipulation planning with embodied world model
IEEE Robotics and Automation Letters, 2026
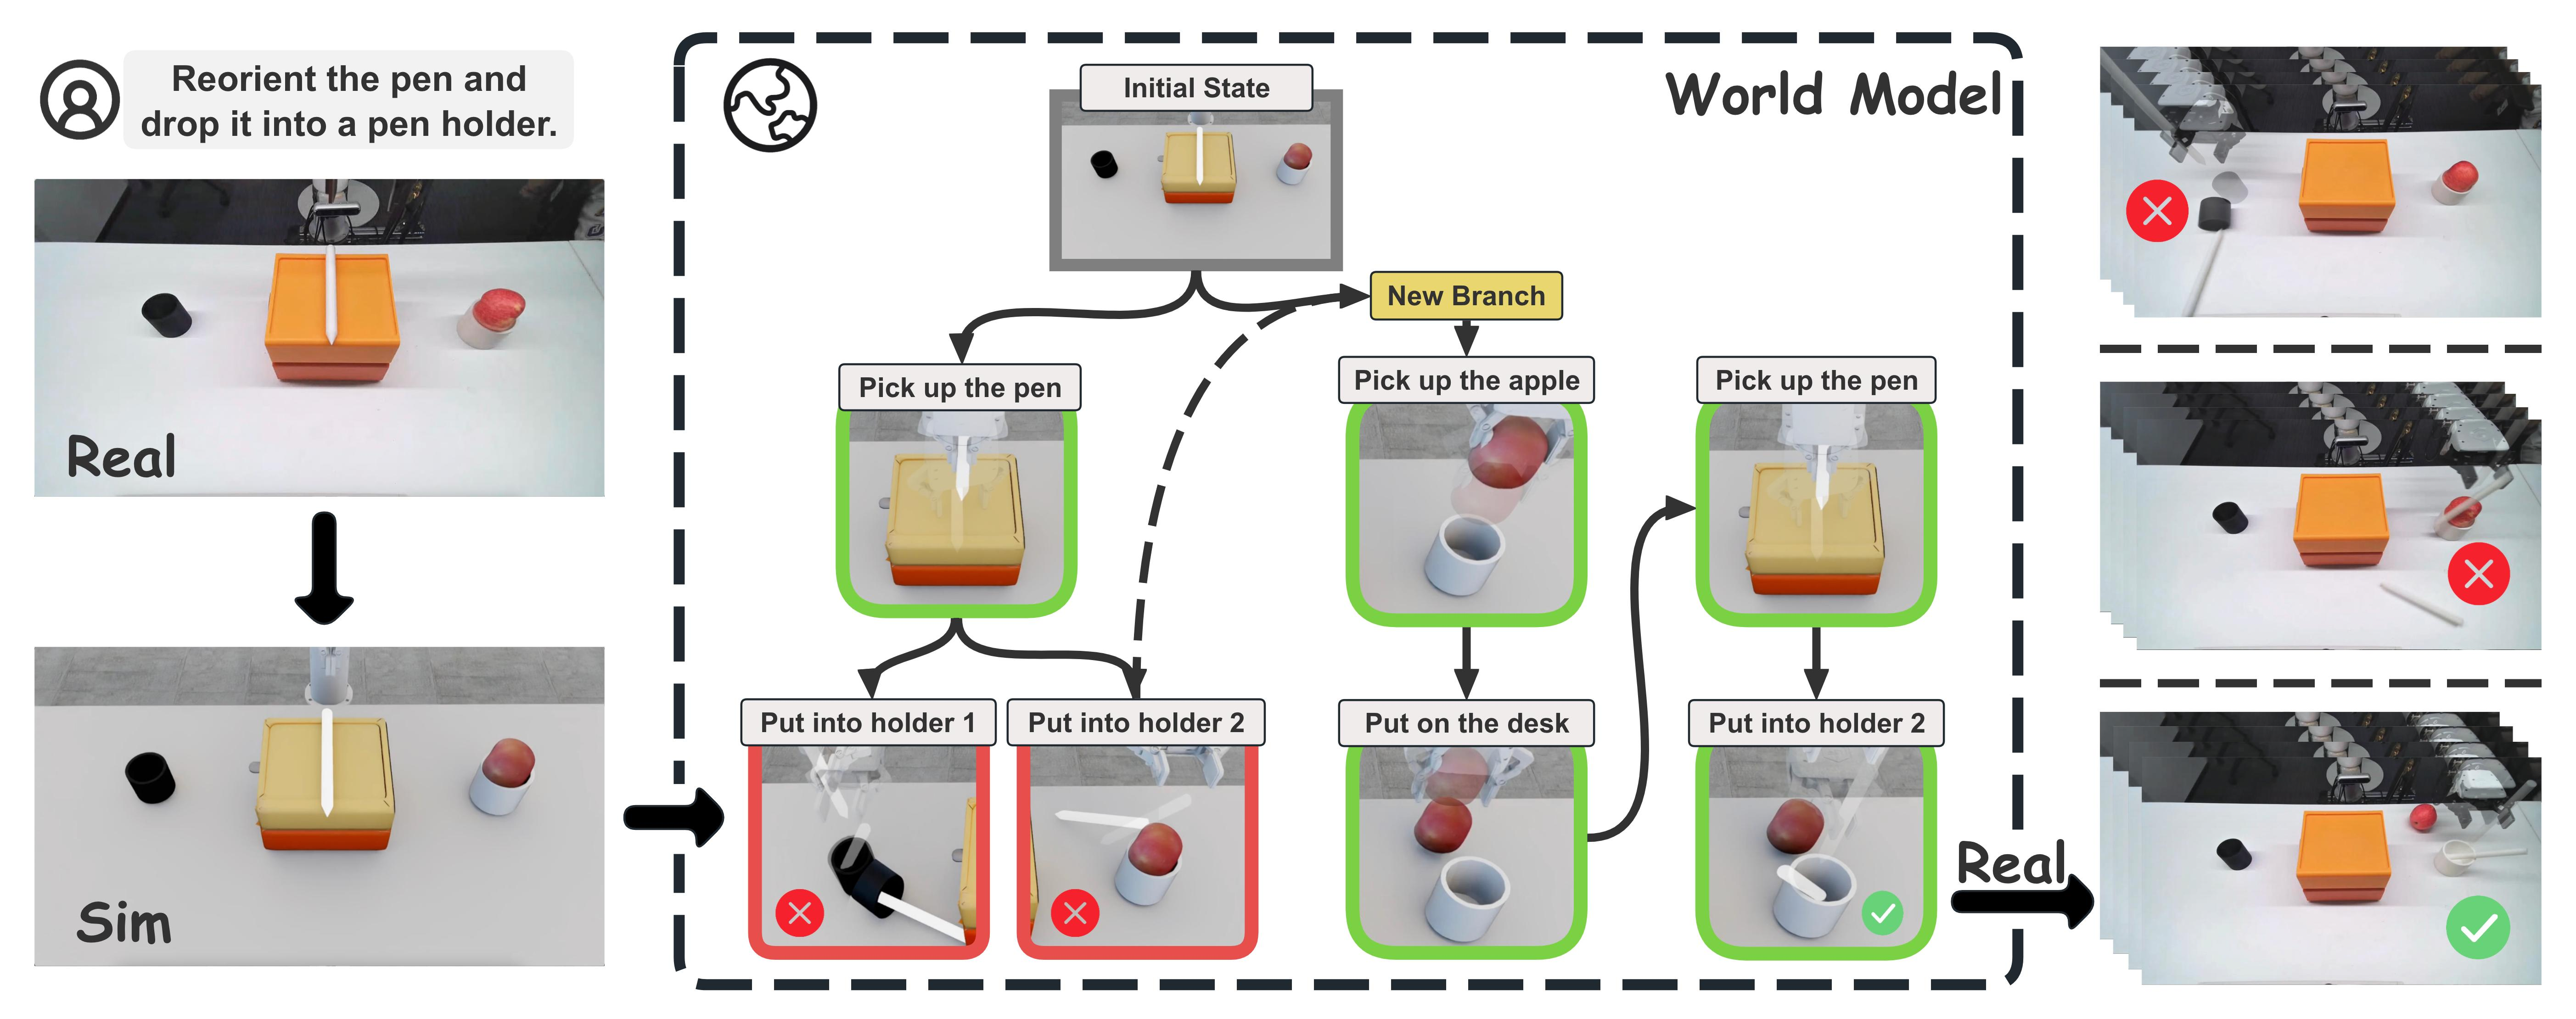
This paper brings tree-structured deliberation into embodied manipulation planning. It couples reasoning over candidate action branches with an embodied world model, enabling the agent to evaluate physical consequences before committing to long-horizon manipulation steps.